GIST AILAB

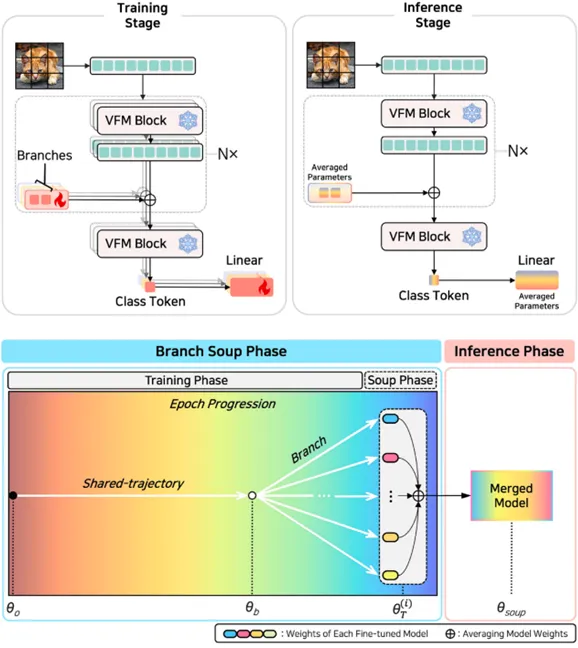
Branch Soup: Improving vision foundation models via averaging adapter weights of branched checkpoints

Youmin Park, Yeonguk Yu, Yunjae Heo, Kyoobin Lee*

Neurocomputing (2026)

Published: 2026. 10. 14.

Branch Soup: Improving vision foundation models via averaging adapter weights of branched checkpoints

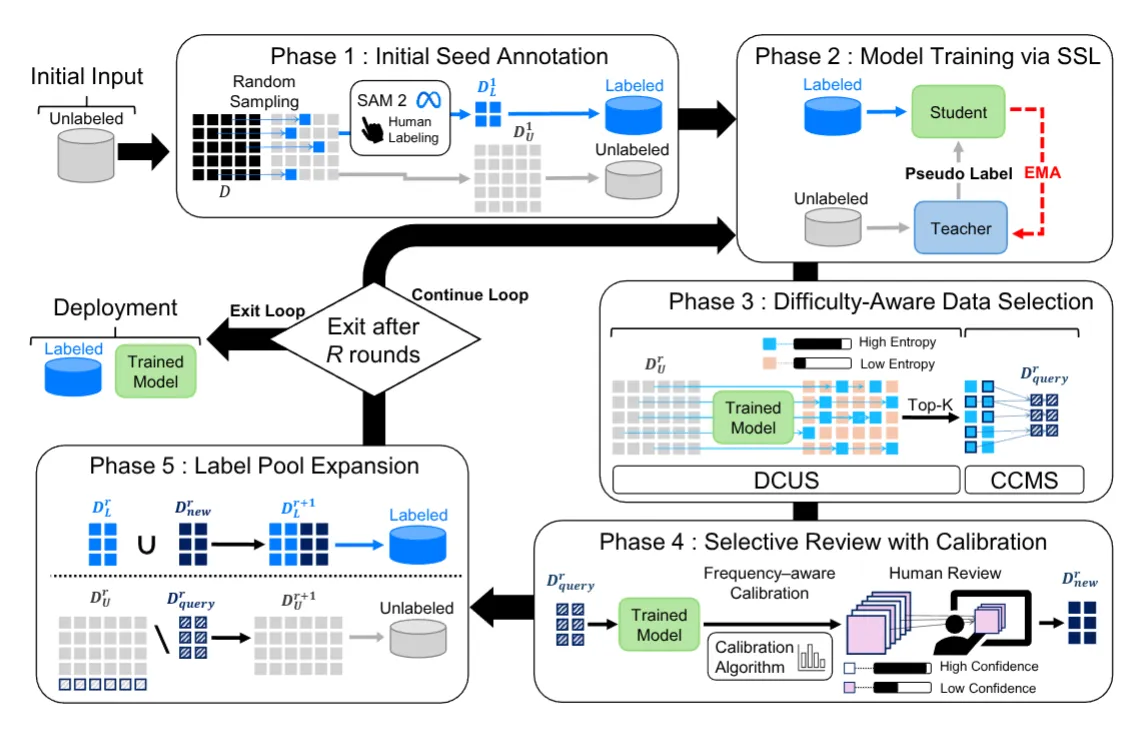
Human-efficient annotation system via active semi-supervised learning and selective review

Jongwon Kim, Youmin Park, Seunghyeok Hyun, Yunjae Heo, Seongju Lee1, Yeonguk Yu2, Kyoobin Lee*

Elsevier Intelligent Systems with Applications (2026)

Published: 2026. 07. 15.

Human-efficient annotation system via active semi-supervised learning and selective review

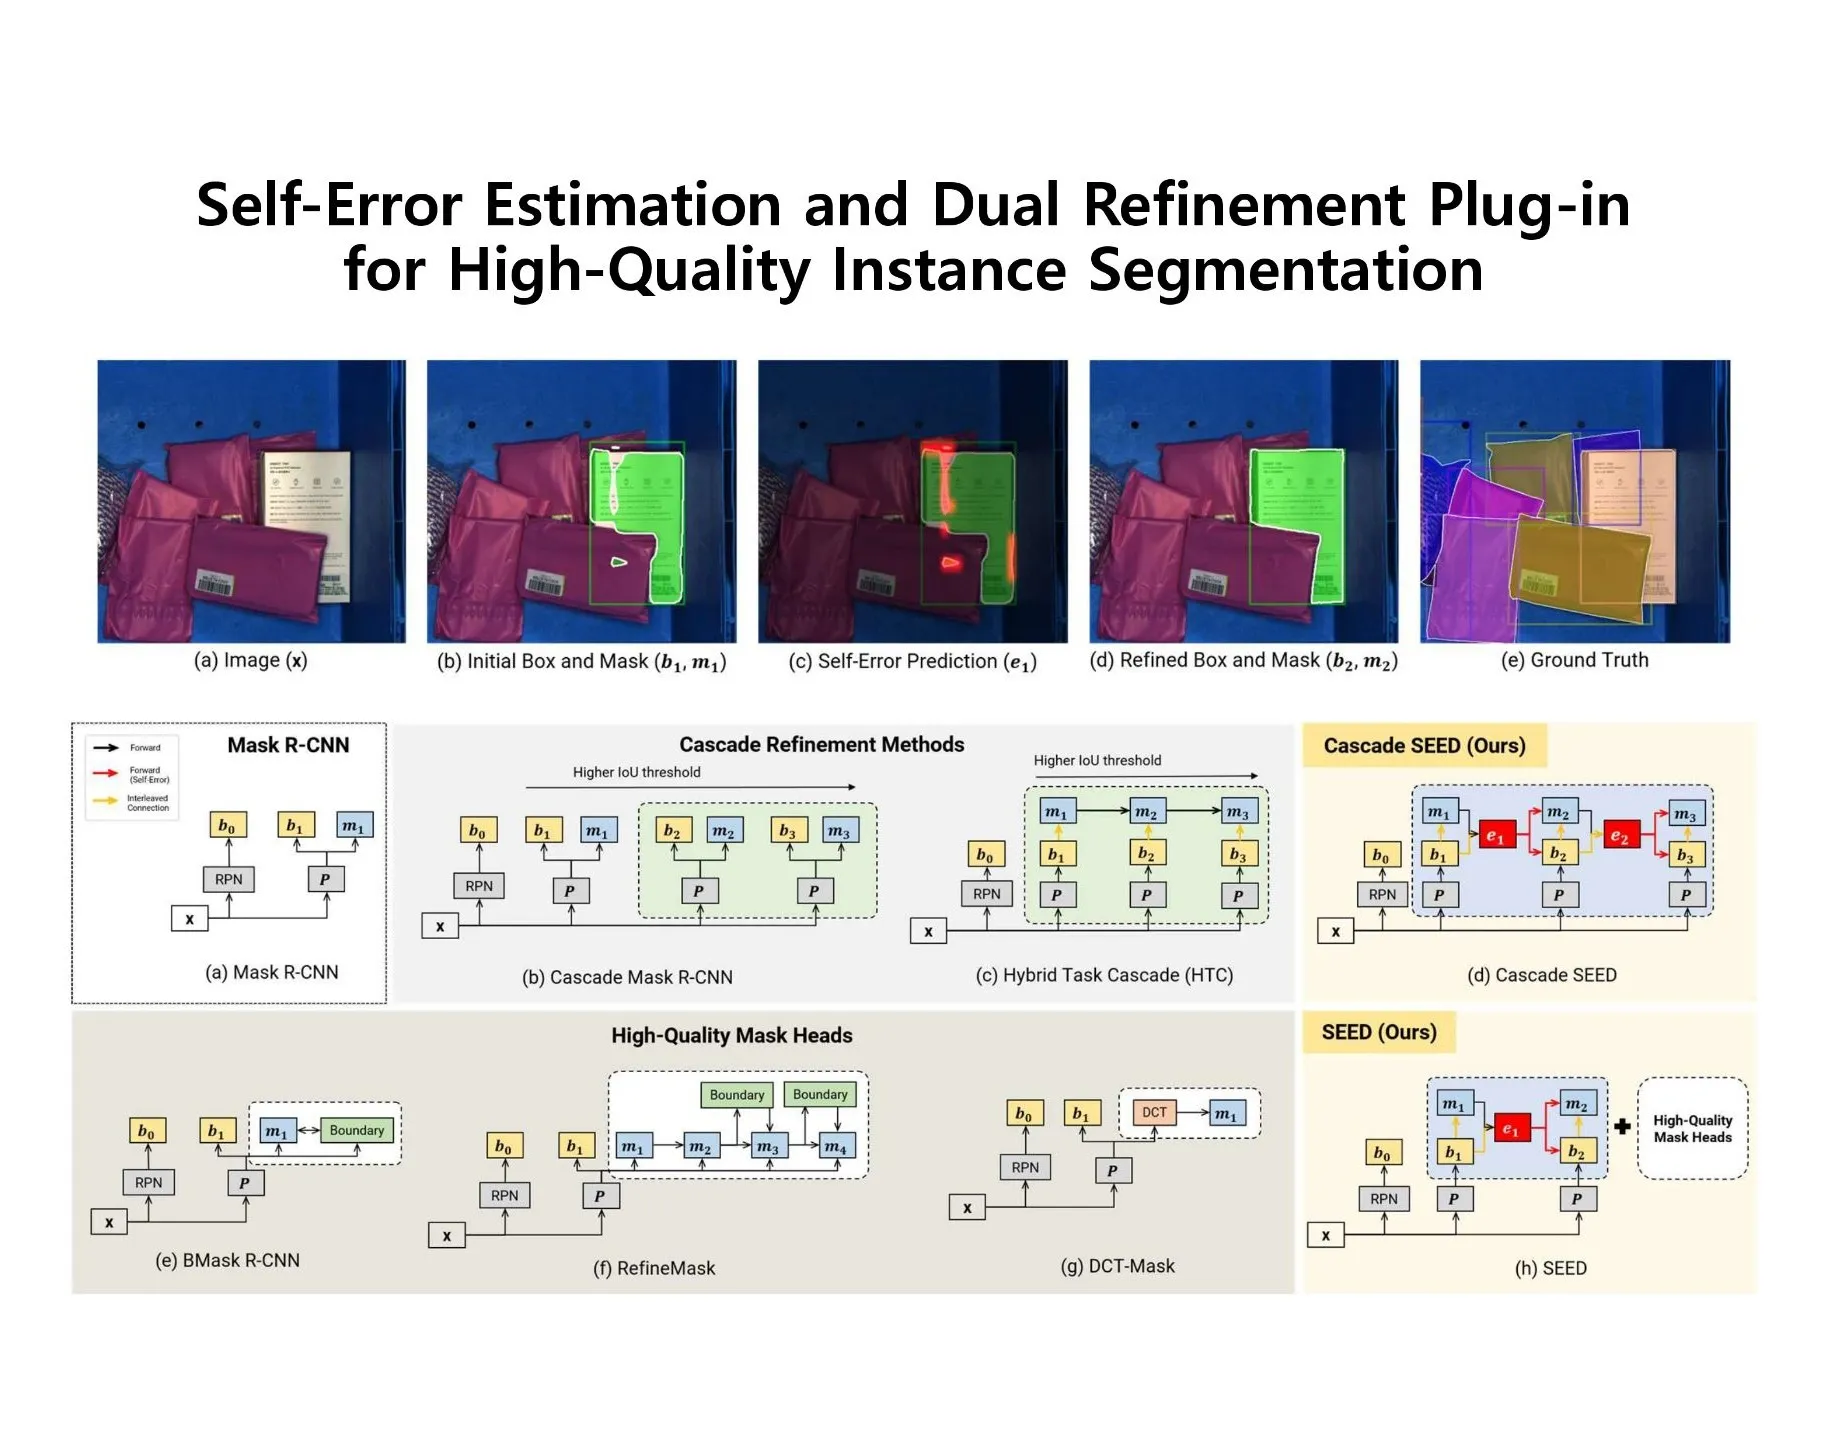
Self-Error Estimation and Dual Refinement Plug-in for High-Quality Instance Segmentation

Sangbeom Lee, Seunghyeok Back, Kangmin Kim, Sungho Shin, Kyoobin Lee*

IEEE Institute of Electrical and Electronics Engineers (2026)

Published: 2026. 05. 21.

Self-Error Estimation and Dual Refinement Plug-in for High-Quality Instance Segmentation

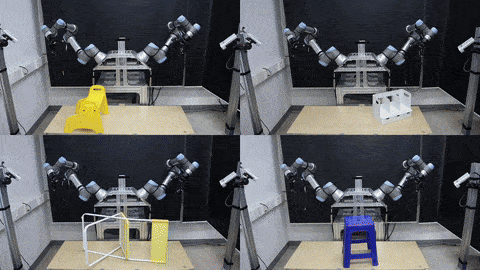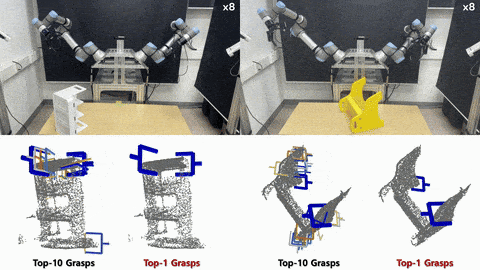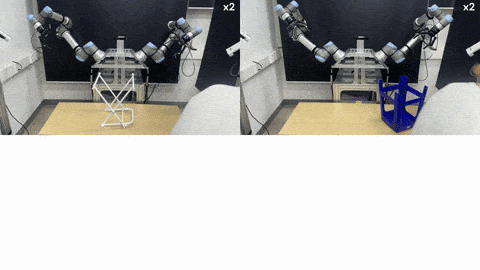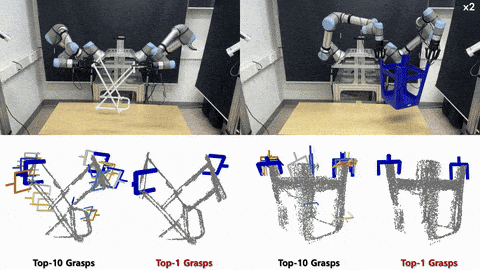
BiGraspFormer: End-to-End Bimanual Grasp Transformer

Kangmin Kim, Seunghyeok Back, Geonhyup Lee, Sangbeom Lee, Sangjun Noh, Kyoobin Lee*

The 2026 IEEE International Conference on Robotics and Automation (ICRA) 2026

Published: 2026. 06. 02.

BiGraspFormer: End-to-End Bimanual Grasp Transformer

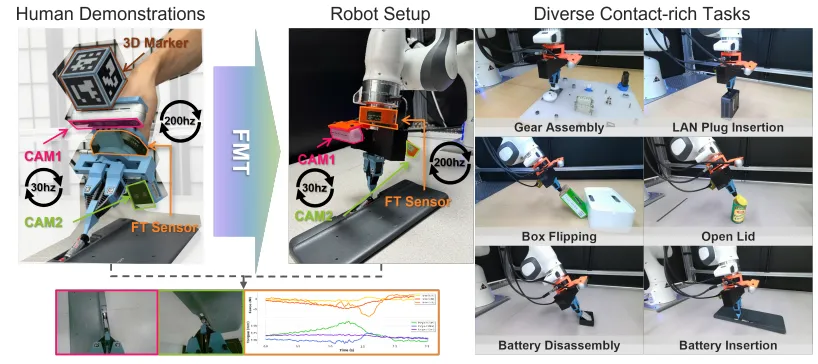
ManipForce: Force-Guided Policy Learning with Frequency-Aware Representation for Contact-Rich Manipulation

Geonhyup Lee, Youngjin Lee, Kangmin Kim, Seongju Lee, Sangjun Noh, Seunghyeok Back and Kyoobin Lee*

The 2026 IEEE International Conference on Robotics and Automation (ICRA) 2026

Published: 2025. 09. 23.

ManipForce: Force-Guided Policy Learning with Frequency-Aware Representation for Contact-Rich Manipulation

CD-FKD: Cross-Domain Feature Knowledge Distillation for Robust Single-Domain Generalization in Object Detection

Junseok Lee1,*, Sungho Shin2,*, Seongju Lee3, Kyoobin Lee3,†

The 2026 IEEE International Conference on Robotics and Automation (ICRA) 2026

Published: 2025. 05. 27.

CD-FKD: Cross-Domain Feature Knowledge Distillation for Robust Single-Domain Generalization in Object Detection

GraspClutter6D: A Large-scale Real-world Dataset for Robust Perception and Grasping in Cluttered Scenes

Seunghyeok Back, Joosoon Lee, Kangmin Kim, Heeseon Rho, Geonhyup Lee, Raeyoung Kang, Sangbeom Lee, Sangjun Noh, Youngjin Lee, Taeyeop Lee and Kyoobin Lee*

IEEE Robotics and Automation Letters (RA-L) 2025 Accepted: 2025. 08. 11. Published: 2025. 08. 20.

GraspClutter6D: A Large-scale Real-world Dataset for Robust Perception and Grasping in Cluttered Scenes

Robust Maritime Object Detection under Adverse Conditions via Joint Semantic Learning without Extra Computational Overhead

Junseok Lee, Seongju Lee, Jongwon Kim, Jumi Park and Kyoobin Lee*

The 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025

Published: 2025.10.23.

Robust Maritime Object Detection under Adverse Conditions via Joint Semantic Learning without Extra Computational Overhead

MV2: A Large-Scale 360-degree Multi-View Maritime Vision Dataset for Object Detection and Segmentation

Junseok Lee, Jongwon Kim, Seongju Lee, Taeri Kim and Kyoobin Lee*

The 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025

Published: 2025.10.22.

MV2: A Large-Scale 360-degree Multi-View Maritime Vision Dataset for Object Detection and Segmentation

Automated Diagnosis for Extraction Difficulty of Maxillary and Mandibular Third Molars and Post-extraction Complications using Deep Learning

Junseok Lee, Jumi Park, Seongju Lee, Seong-Yong Moon and Kyoobin Lee*

Scientific Reports 2025 Accepted: 2025. 04. 25. Published: 2025. 05. 30.

High-Quality Unknown Object Instance Segmentation via Quadruple Boundary Error Refinement

Back Seunghyeok, Sangbeom Lee, Kangmin Kim, Joosoon Lee, Sungho Shin, Jemo Maeng and Kyoobin Lee*

The 2025 IEEE International Conference on Robotics and Automation (ICRA) 2025

Published: 2025. 05. 22.

High-Quality Unknown Object Instance Segmentation via Quadruple Boundary Error Refinement

GraspSAM: When Segment Anything Model Meets Grasp Detection

Sangjun Noh, Jongwon Kim, Dongwoo Nam, Seunghyeok Back, Raeyoung Kang and Kyoobin Lee*

The 2025 IEEE International Conference on Robotics and Automation (ICRA) 2025

Curriculum Fine-tuning of Vision Foundation Model for Medical Image Classification Under Label Noise

Yeonguk Yu, Minhwan Ko, Sungho Shin, Kangmin Kim and Kyoobin Lee*

Conference on Neural Information Processing Systems (NeurIPS) 2024

Published: 2024. 12. 15.

Curriculum Fine-tuning of Vision Foundation Model for Medical Image Classification Under Label Noise

MART: MultiscAle Relational Transformer Networks for Trajectory Prediction

Seongju Lee, Junseok Lee, Yeonguk Yu, Taeri Kim, and Kyoobin Lee*

European Conference on Computer Vision (ECCV) 2024

Published: 2024. 10. 02.
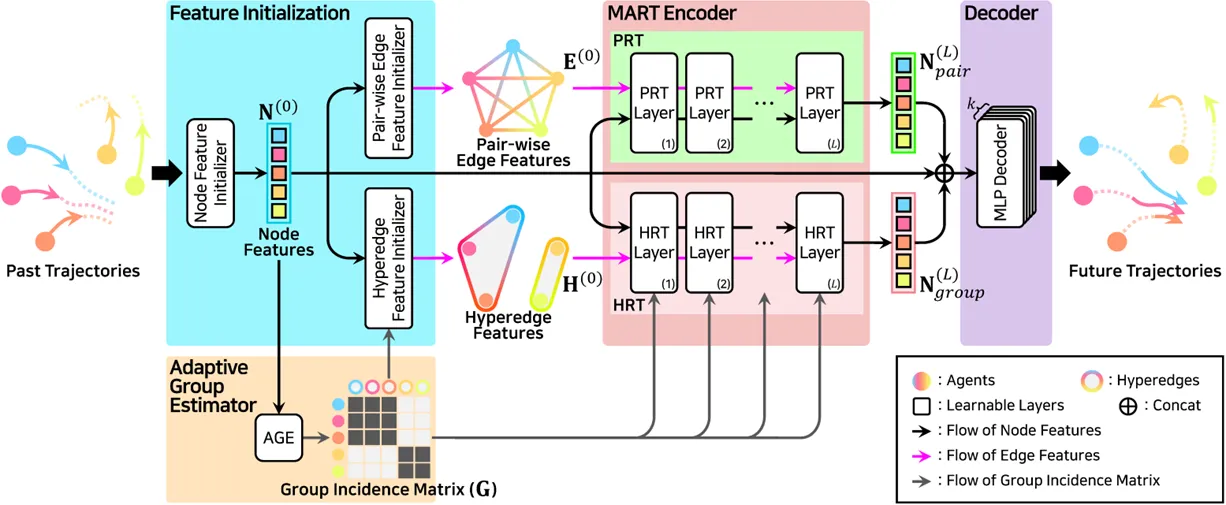
MART: MultiscAle Relational Transformer Networks for Trajectory Prediction

PolyFit: A Peg-in-hole Assembly Framework for Unseen Polygon Shapes via Sim-to-real Adaptation

Geonhyup Lee, Joosoon Lee, Sangjun Noh, Minhwan Ko, Kangmin Kim and Kyoobin Lee*

Conference on Intelligent Robots and Systems (IROS) 2024

Published: 2024. 10. 14.

PolyFit: A Peg-in-hole Assembly Framework for Unseen Polygon Shapes via Sim-to-real Adaptation

Domain-Specific Block Selection and Paired-View Pseudo-Labeling for online Test-Time Adaptation

Yeonguk Yu, Sungho Shin, Seunghyeok Back, Minhwan Ko, Sangjun Noh and Kyoobin Lee*

2024 The IEEE/CVF Conference on Coumputer Vision and Pattern Recognition (CVPR 2024)

Published: 2024. 06. 21.

Domain-Specific Block Selection and Paired-View Pseudo-Labeling for online Test-Time Adaptation

Learning to Place Unseen Objects Stably using a Large-scale Simulation

Sangjun Noh*, Raeyong Kang*, Taewon Kim*, Seungheok Back, Seungho Bak, and Kyoobin Lee*

IEEE Robotics and Automation Letters (RA-L) (I.F. 5.2) 2024 Accepted: 2024. 01. 08. Published: 2024. 03.

Learning to Place Unseen Objects Stably using a Large-scale Simulation

SleePyCo: Automatic Sleep Scoring with Feature Pyramid and Contrastive Learning

Seongju Lee, Yeonguk Yu, Seunghyeok Back, Hogeon Seo, and Kyoobin Lee*

Expert Systems with Applications (ESWA) (I.F. 8.5) 2023 Accepted: 2023. 11. 09. Published: 2024. 04.
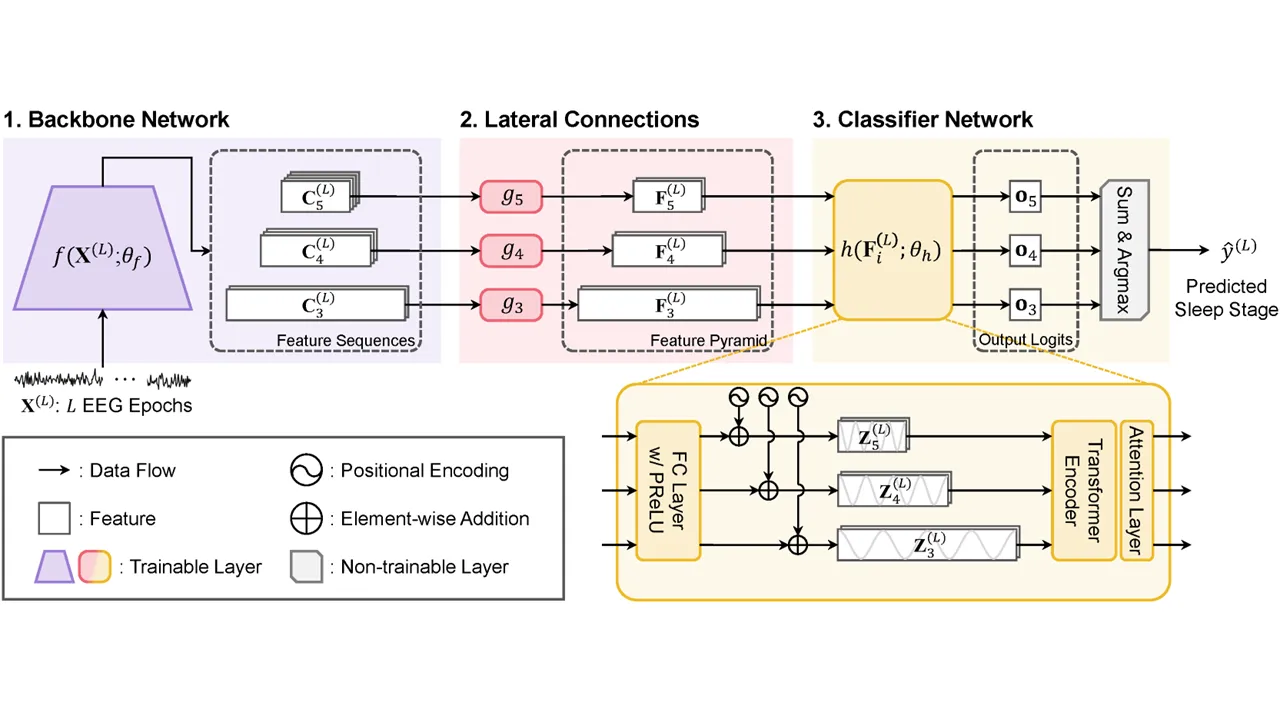
SleePyCo: Automatic Sleep Scoring with Feature Pyramid and Contrastive Learning

Block Selection Method for Using Feature Norm in Out-of-Distribution Detection

Yeonguk Yu, Sungho Shin, Seongju Lee, Changhyun Jun, and, Kyoobin Lee*

2023 The IEEE/CVF Conference on Coumputer Vision and Pattern Recognition (CVPR 2023)

Published: 2023. 06. 18.

Block Selection Method for Using Feature Norm in Out-of-Distribution Detection

Teaching Where to Look: Attention Similarity Knowledge Distillation for Low Resolution Face Recognition

Sungho Shin, Joosoon Lee, Junseok Lee, Yeonguk Yu, Kyoobin Lee*

European Conference on Computer Vision (ECCV 2022)

Published: 2022. 01.

Teaching Where to Look: Attention Similarity Knowledge Distillation for Low Resolution Face Recognition

Unseen Object Amodal Instance Segmentation via Hierarchical Occlusion Modeling

Seunghyeok Back, Joosoon Lee, Taewon Kim, Raeyoung Kang, Sungho Bak, Sangjun Noh, Kyoobin Lee*

accepted at 2022 IEEE International Conference on Robotics and Automation (ICRA 2022) [[paper]](https://arxiv.org/abs/2109.11103) [video] [project website] [[code]](https://github.com/gist-ailab/uoais)

Published: 2022. 05.

Unseen Object Amodal Instance Segmentation via Hierarchical Occlusion Modeling

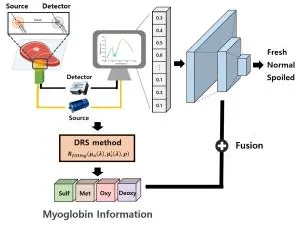
Rapid and Non-Destructive Spectroscopic Method for Classifying Beef Freshness using a Deep Spectral Network Fused with Myoglobin Information

Sungho Shin*, Youngjoo Lee*, Sungchul Kim, Seungjun Choi, Jae Gwan Kim*, Kyoobin Lee*

Food Chemistry (IF:7.514, 4.55% Food Science & Technology) 2021 Accepted: 2021. 02. 07. Published: 2021. 08.

Rapid and Non-Destructive Spectroscopic Method for Classifying Beef Freshness using a Deep Spectral Network Fused with Myoglobin Information

Acceleration of Actor-Critic Deep Reinforcement Learning for Visual Grasping in Clutter by State Representation Learning Based on Disentanglement of a Raw Input Image

Taewon Kim, Yeseong Park, Youngbin Park, Il Hong Suh

accepted at 2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2021)

Acceleration of Actor-Critic Deep Reinforcement Learning for Visual Grasping in Clutter by State Representation Learning Based on Disentanglement of a Raw Input Image